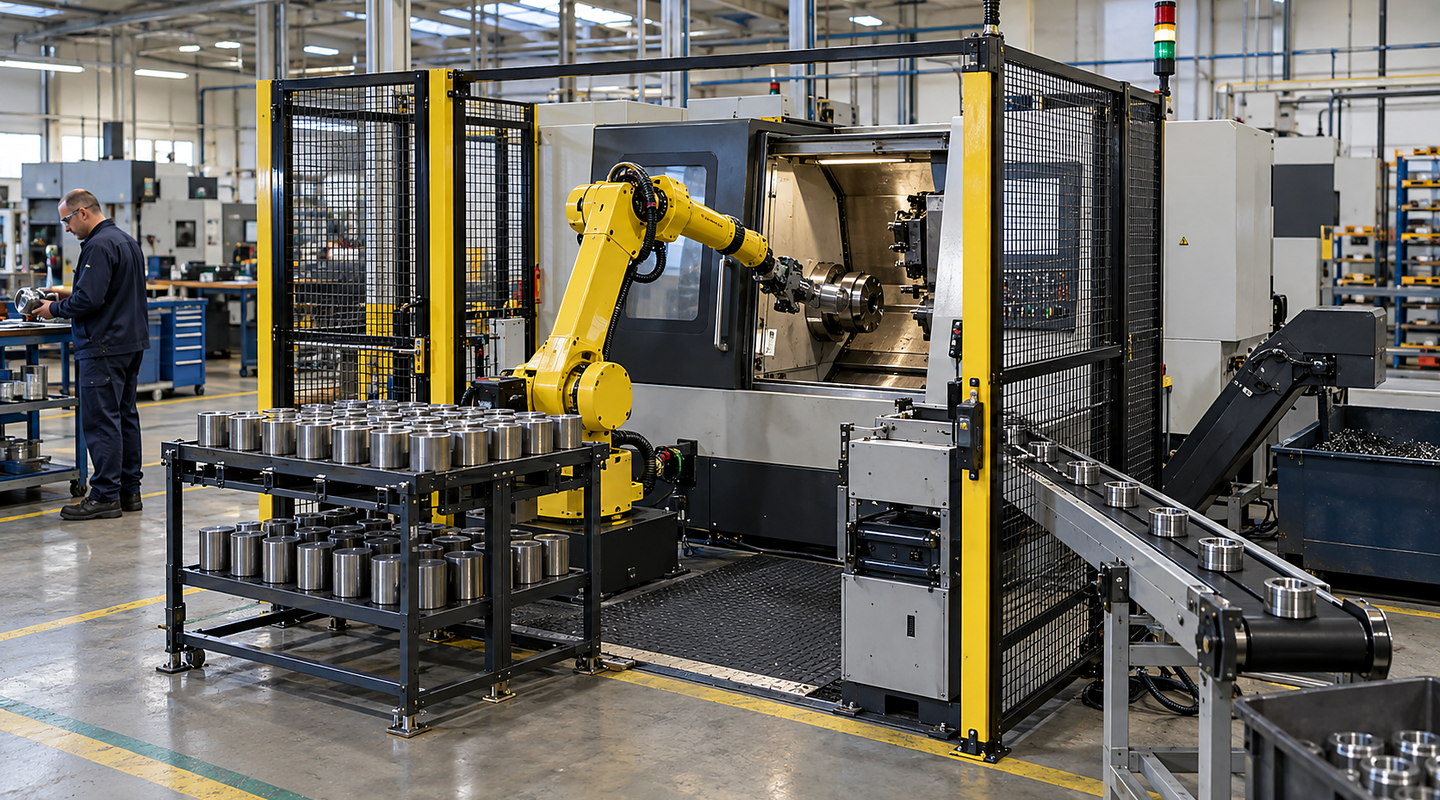
Robotic Test Automation: How the Process Works
Follow the operating sequence for robotic test automation, from preparing the input and controlling the main task to handling exceptions and checking results.
Robotic test automation here means loading and unloading a defined manufacturing functional test while keeping each component linked to its result. Map identification, fixture loading, connection, testing, disconnection and release as one sequence, with the conditions required for a valid test.
Define the tester interface and distinguish a failed test from a missing or incomplete result before routing the part. The test-cell integration guide and acceptance guide connect interface responsibilities with the evidence to review.
Understand the complete route from input to accepted output — Robotic Test Automation
Follow the identified component from arrival to its approved destination. Record the fixture or nest, requested recipe and result throughout the sequence. Reaching a robot position does not demonstrate a correctly seated, connected or validly tested part.
Discuss your application

Four clear stages for robotic test automation
At each stage, you can review how part, product and process variation for robotic loading of functional tests and run-off criteria and production evidence affect the next commitment.
- 01
Observe the Current Process and Collect Representative Samples
Collect representative components, fixture details, connector or probe requirements, tester interface documentation and the current cycle breakdown. Include the intended part and recipe range, pass and fail examples, interrupted-test cases and the required result-storage arrangement.
- 02
Prove Handling and Process Risks in a Focused Feasibility Trial
Assess location, seating, connection and release using representative part variation and the tester conditions needed for a valid result. Agree an assessed method for reviewing uncertain loading, interrupted connections and missing results before drawing conclusions about the complete cell.
- 03
Design and Build the Complete Guarded Cell
Allocate fixture, tester and cell responsibilities for ready, loaded, start, busy, complete, fault and result states as applicable. Agree identity and recipe association, acknowledgements, timeouts and the rules for passed, failed and unresolved parts.
- 04
Run Agreed Scenarios and Support Production Ramp-Up
Record results for the agreed part range and complete production pattern, including connection, test duration, unloading and result confirmation. Include assessed fault recovery, authorised retests and unresolved-part routing, with training and remaining actions visible at handover.
Decisions and results stay connected
| Stage | What happens | What you can review |
|---|---|---|
| Observe the Current Process and Collect Representative Samples | Confirm the requirements for robotic loading of functional tests, the operating range and the definition of a good result. | Your samples, current information and any points that still need confirming. |
| Prove Handling and Process Risks in a Focused Feasibility Trial | Compare workable methods using part, product and process variation for robotic loading of functional tests and arrival pattern and presentation from your real production. | The trial method, observations and reason for the recommended route. |
| Design and Build the Complete Guarded Cell | Resolve required cycle and production pattern, tooling, sensing and process interfaces and the physical, control, safety and data connections. | The agreed layout, line connections and any changes from the proposal. |
| Run Agreed Scenarios and Support Production Ramp-Up | Check normal, difficult and fault conditions before your team takes over the system. | Results for operator access, recovery and changeover and run-off criteria and production evidence, plus actions and operating information. |
Keep connected responsibilities clear
Your final robotic test automation scope must also account for operator access, recovery and changeover, run-off criteria and production evidence, current regulations and the conditions at your site.
- Cycle time depends on the complete process rather than robot speed alone.
- Part presentation, tolerances and recovery cases must be included in feasibility work.
- Collaborative operation or automatic handling cannot be assumed safe without an application assessment.